Showing posts with label Future. Show all posts

Monday, August 15, 2016

DuoSkin | Temporary Tattoo to Control Connected Interfaces


Microsoft Research and MIT Media Lab recently introduced a new product called DuoSkin. DuoSkin is basically a temporary tattoo that will allow you to control connected interfaces. For example, you can use it to control a game or even your smartphone. Additionally, you can use DuoSkin as an NFC tag, which you can easily use with your smartphone.


For more information: DuoSkin

Sunday, March 6, 2016

Support Group for Bots: Coping with Humans

IBM Watson is a cognitive system that''s ushering in the new era of cognitive business. Recently, a group of battered science fiction bots spoke about their yen to take over the world and their dislike for working with humans. Unlike them, Watson works with humans to out-think competitors, challenges, limits.


Monday, March 16, 2015

DARPA Robotics Challenge Finals

NASA's quadrupedal RoboSimian
The DRC is a competition of robot systems and software teams vying to develop robots capable of assisting humans in responding to natural and man-made disasters. It was designed to be extremely difficult. Participating teams, represent some of the most advanced robotics research and development organizations in the world, 

To qualify for the DRC Finals, the teams had to submit videos showing successful completion of five sample tasks: engage an emergency shut-off  switch, get up from a prone position, loco-mote ten meters without falling, pass over a barrier, and rotate a circular valve 360 degrees.

25 teams will compete during the two-day event, to be held June 5-6, 2015, at Fairplex in Pomona, California.

DARPA Robotics Challenge

Monday, January 5, 2015

2015 Top 10 Tech Tips for Resolution

We computed your Top 10:

1. Check your backup procedure: Backup solutions are not a “set it and forget it” process. Definitely need to verify the process is still working and that the destinations drive(s) are functioning.

2. Check your anti-virus software program: Make sure it is up to date, that it is scanning regularly. (Microsoft Security Essentials is available to small businesses on up to 10 PCs for free)

3. Tidy the desktop: Clear off old icons, files, and folders.

4. Organize: Keep your computer software all in one place and easily accessible.

5. Insurance: Inventory all your computing hardware.

6. Establish one location: Use one notebook, one folder, whatever it may be, for all your User ID’s, login passwords, email passwords, router settings and anything to do with computing.

7. Change passwords: Time for a better password then yesterday. Help keep the bad guys out of your account by using both your password and your phone. Always sign up for 2-Step verification.

8. Replace power strips: Use a power surge protector. Power strips are great for plugging in lamps, speakers, pencil sharpeners, but not your monitors, routers, backup drives, computers, etc.

9. Replace worn devices: All computing devices fail.

10. Maintenance your computers: Every 3-6 months - clean out temp files, patch it, updated it, stop unwanted startup programs, check the antivirus and backup process.

These 2015 Top 10 tech tips for resolution have been brought to you by tech3Support. Happy shiny new tech year. Best of luck with your other resolutions too.

Sunday, September 21, 2014

Robot Pilots

In this video, the pilot is itself a humanoid robot, learning how to fly an airplane in a flight simulator. With a panel of controls in its mechanical fingers, the PIBOT uses visual information, presented on a computer monitor, to inform its flying. 
Right now, the concept is limited to piloting simulators, but the researchers hope to have PIBOT actually steer a plane some day.

Thursday, August 14, 2014

The Kilobot Project

Harvard researchers designed the Kilobot, a low-cost robot designed to make testing collective algorithms on hundreds or thousands ("kilos") of robots. Each robot has the basic capabilities required for a swarm robot, but is made with low-cost parts, and is mostly assembled by an automated process. 

In addition, the system design allows a single user to easily and scalably operate a large Kilobot collective, such as programming, powering on, and charging all robots systems. The researchers are now using the Kilobot swarm to investigate algorithms for robust collective behavior, such as collective transport, human-swarm interaction, and shape self-assembly, as well as new theory that links individual robot capabilities to achievable swarm behaviors.


Wednesday, July 2, 2014

Muscle-Powered Bio-Bots

Engineers at the University of Illinois at Urbana-Champaign demonstrated a class of walking “bio-bots” powered by muscle cells and controlled with electrical pulses, giving researchers unprecedented command over their function.

“This work represents an important first step in the development and control of biological machines that can be stimulated, trained, or programmed to do work. It's exciting to think that this system could eventually evolve into a generation of biological machines that could aid in drug delivery, surgical robotics, 'smart' implants, or mobile environmental analyzers, among countless other applications.”


via New Bureau | Illinois

Wednesday, May 21, 2014

DNA Nano Device Sequencer

A multidisciplinary team of Brigham Young University scientists has developed a way to significantly reduce cell death when introducing DNA into egg cells. The researchers have created a microscopic lance that delivers DNA to the cells through electrical forces.

“Because DNA is naturally negatively charged, it is attracted to the outside of the lance using positive voltage,” said Brian Jensen, BYU professor of mechanical engineering. “Once we insert the lance into a cell, we simply reverse the polarity of the electrical force and the lance releases the DNA.”


Read more...

Thursday, January 30, 2014

Monday, January 6, 2014

iREX 2013 Robot Mashup


Countless robots were on display at the International Robot Exhibition in Tokyo. Here is the best of the IREX robots, all mashed up. 


Tuesday, September 3, 2013

Wearable Authentication Device | Utilizes Your Electrocardiogram (ECG)

Bionym has developed the first wearable authentication device that utilizes a user's Electrocardiogram (ECG) to validate a person’s identity. The Nymi has two electrodes, one on the wrist and one on the top. To authenticate, a user must attach the Nymi, and then place their finger on the top electrode to complete the electric current. A user only needs to validate their identity once, until the Nymi is removed. The closed loop keeps the Nymi in an authenticated state, removing all need for repeated prompts (such as in fingerprint scanning or PIN requests).


Once authenticated, the Nymi communicates the user’s identity to a device (such as a smartphone, vehicle, elctronic lock, or even a smart environtment) using Bluetooth Low Energy (BLE). The Nymi not only uses the BLE to reliably communicate with the world, but it also uses it to sense how far away it is from devices (proximity detection). The Nymi allows users to interact with the world as a person, not as a number.

via Bionym

Thursday, July 25, 2013

G.I. Joe Bot

In 20 to 40 years, humanoid robots, using human tools, could precede soldiers into dangerous areas, performing tasks such as turning a wrench to open valves, opening doors and climbing ladders. Some day, the Army might send autonomous robots into battle to physically engage with the enemy.

To get some of the “smarts” into the robots, the Army is working with 5D Robotics Inc., a robotics software company, which in turn is working with DRS Technologies and Segway Inc. 5D said it is trying to integrate human behaviors into robots, such as robotic assistants that carry soldier’s packs or small wheeled robots the size of a big shoe box that can carry cameras into dangerous areas.

Jackie Fenn, an analyst with Gartner Inc., said the hardest part about building military robots will be making them able to move easily and quickly over tough, often dangerous, terrain. That, she added, will be harder to do than making them smart enough to act autonomously.

The largest unmanned vehicle ever deployed with U.S. ground forces, the Lockheed Martin Squad Mission Support System leverages robotic technologies for unmanned transport and logistical support for light, early entry and special operations forces. It solves capability gaps by lightening the Soldier’s load and serving as a power management resource.

via Computerworld

Sunday, June 30, 2013

DARPA Robotic Challenge

The DARPA Robotic Challenge will focus on developing robots that can operate in rough terrain and austere conditions, using aids (vehicles and hand tools) commonly available in populated areas. Specifically, proving that the following capabilities can be accomplished:

1. Compatibility with environments engineered for humans (even if they are degraded)
2. Ability to use a diverse assortment of tools engineered for humans (from screwdrivers to vehicles)
3. Ability to be supervised by humans who have had little to no robotics training.

Supervised autonomy is critical, as it allows simple tasks to be performed by the robot without full-time operator intervention. This will be especially important in unreliable communications environments.

DARPA-Developed Tools:
DRC Simulator: To facilitate robot software development, DARPA is developing an open source simulation tool: the DRC Simulator. The Simulator will be populated with models of robots, robot components, and field environments and will be made available to organizations skilled in robotic software development. This simulator will help to expand the supplier base for ground robot systems (both hardware and software), increase capabilities, and in the future will help lower acquisition costs.

Atlas: The most successful teams (Track B and C) in the Virtual Robotics Challenge will be given a humanoid robot called Atlas. Atlas is one of many robots being developed to complete the physical tasks planned for the DARPA Robotics Challenge Trials and Finals events, and requires software expertise to program the robot to accomplish the objectives.


Tuesday, June 11, 2013

Robot Touch Screen

Microsoft Research's prototype of a haptic feedback touch screen called TouchMover.

Researchers uploaded a full set of MRI brain scans and demoed how doctors might scroll through them and annotate specific slides. And with some additional programming, the researchers could also make the TouchMover provide haptic feedback based on the material properties and texture of the skull bone and pulpy brain tissue, making the screen feel like palpating an actual brain.

Monday, May 27, 2013

X-47B: Unmanned Combat Air System


The X-47B is an unmanned combat air system carrier (UCAS) being developed by Northrop Grumman for the US Navy (USN). The strike fighter size unmanned aircraft is currently in its demonstration phase. The unmanned aircraft was first developed as part of the X-47 program.
Air worthiness of the X-47B unmanned combat air system demonstrator was developed at an estimated cost of $813m. The aircraft performed a successful initial test flight at Patuxent River, Maryland, in July 2012. The X-47B is expected to enter active naval service by 2019.
The video below demonstrates the first time any unmanned aircraft has completed a touch and go landing at sea.
An X-47B Unmanned Combat Air System (UCAS) demonstrator conducts a touch and go landing on the flight deck of the aircraft carrier USS George H.W. Bush (CVN 77)

Sunday, April 21, 2013

BlabDroids

BlabDroids, (little robot cameras), filming their own documentary, asking questions of whoever decides to pick them up and chat with them:

Monday, March 18, 2013

Winners of the 2013 Skyscraper Competition

eVolo Magazine announced the winners of their 2013 Skyscraper Competition. The award was established in 2006 to recognize outstanding ideas for vertical living. Since then, the publication has received more than 5,000 projects that envision the future of building high. These ideas, through the novel use of technology, materials, programs, aesthetics, and spatial organizations, challenge the way we understand vertical architecture and its relationship with the natural and built environments.

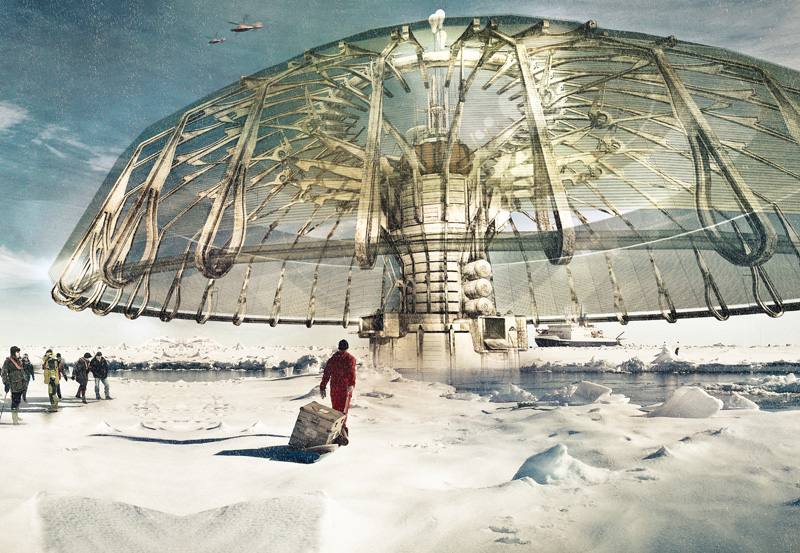
The first place was awarded to Derek Pirozzi from the United States, for his project “Polar Umbrella”. The proposal is a buoyant skyscraper that rebuilds the arctic ice caps by reducing the surface’s heat gain and freezing ocean water. In addition, the super-structure is equipped with a desalinization plant and solar powered research facilities and eco-tourist attractions.


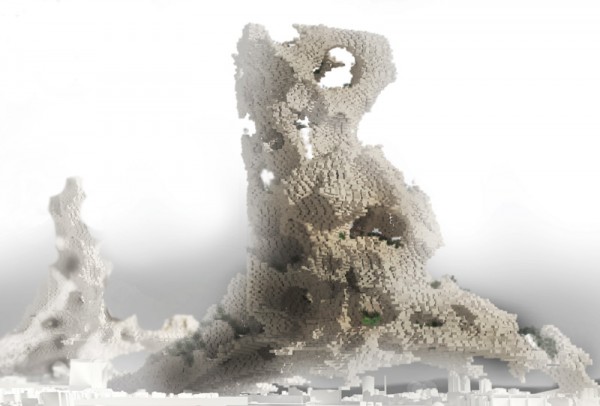
Second place are Darius Maïkoff and Elodie Godo from France, for their “Phobia Skyscraper”. The project seeks to revitalize an abandoned industrial area of Paris, France, through an ingenious system of prefabricated housing units. Its modularity allows for a differentiation of various programs and evolution in time.


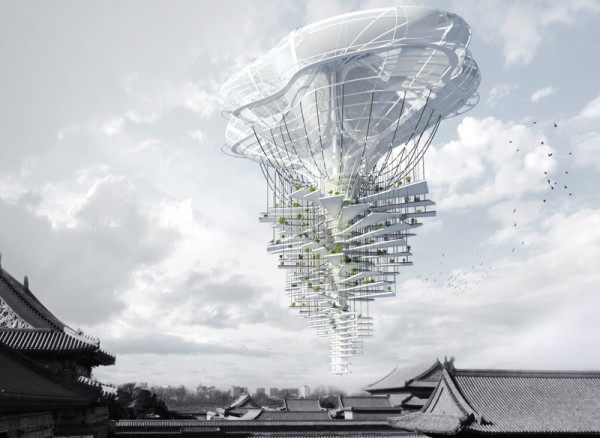
The third place was awarded to Ting Xu and Yiming Chen from China, for their project “Light Park”, a floating skyscraper that takes new development within large cities to the sky. The project allows for a continuous growth of the world’s mega-cities by providing adequate infrastructure, housing, commercial, and recreational areas.


Go to eVolvo for the honorable mentions.